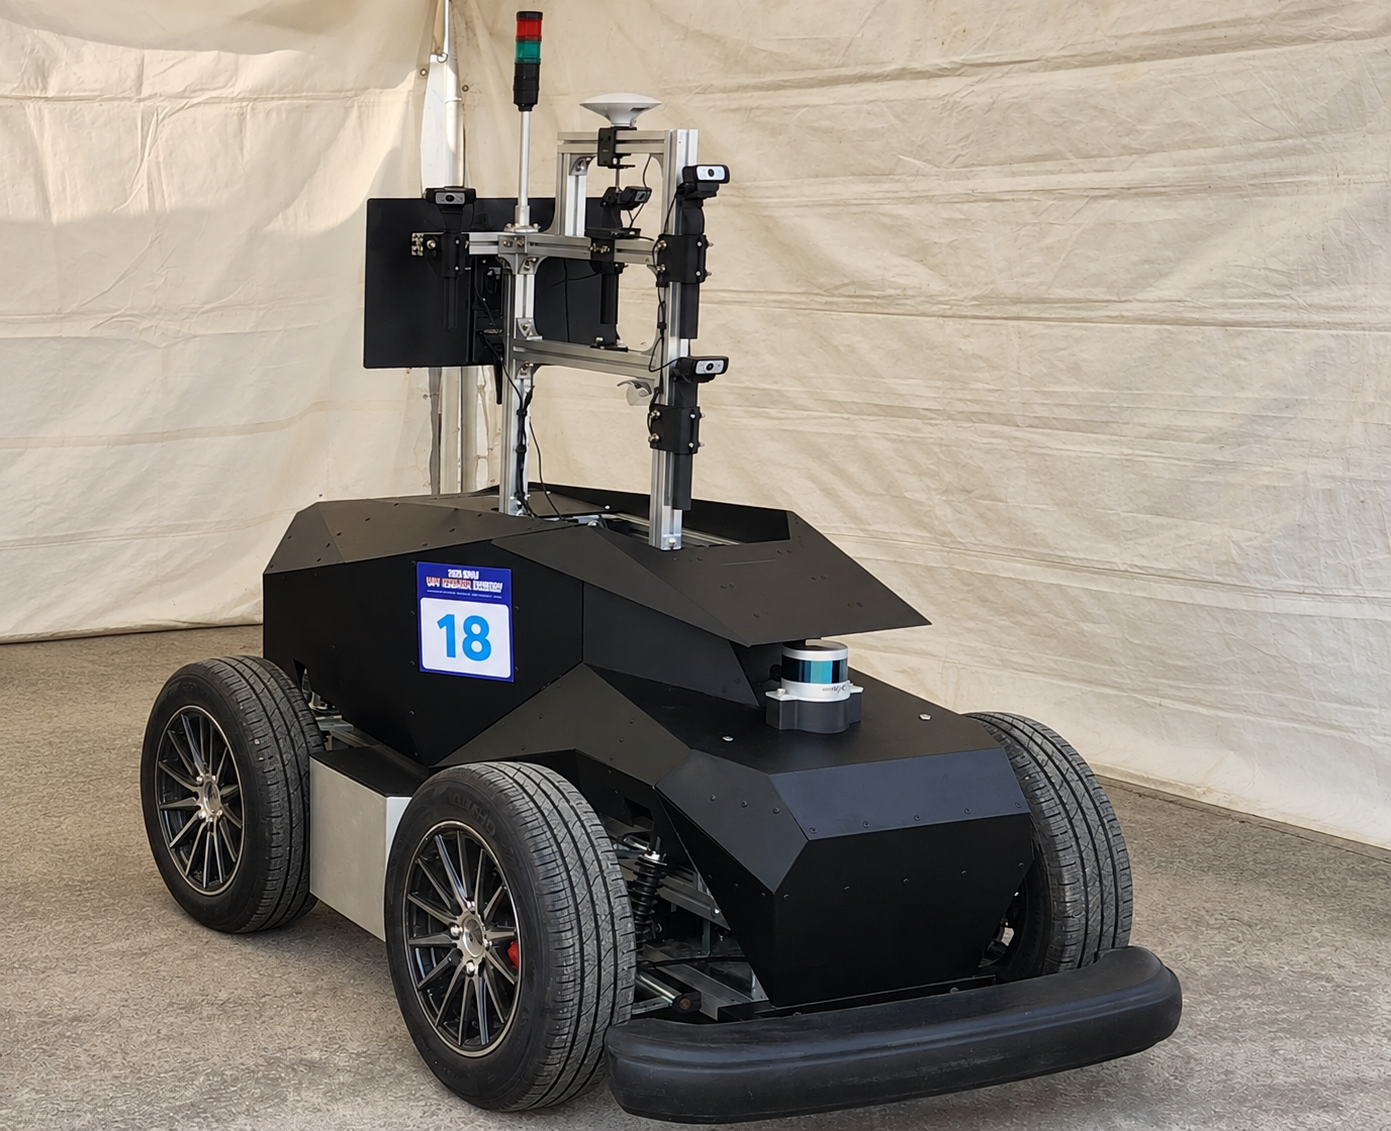
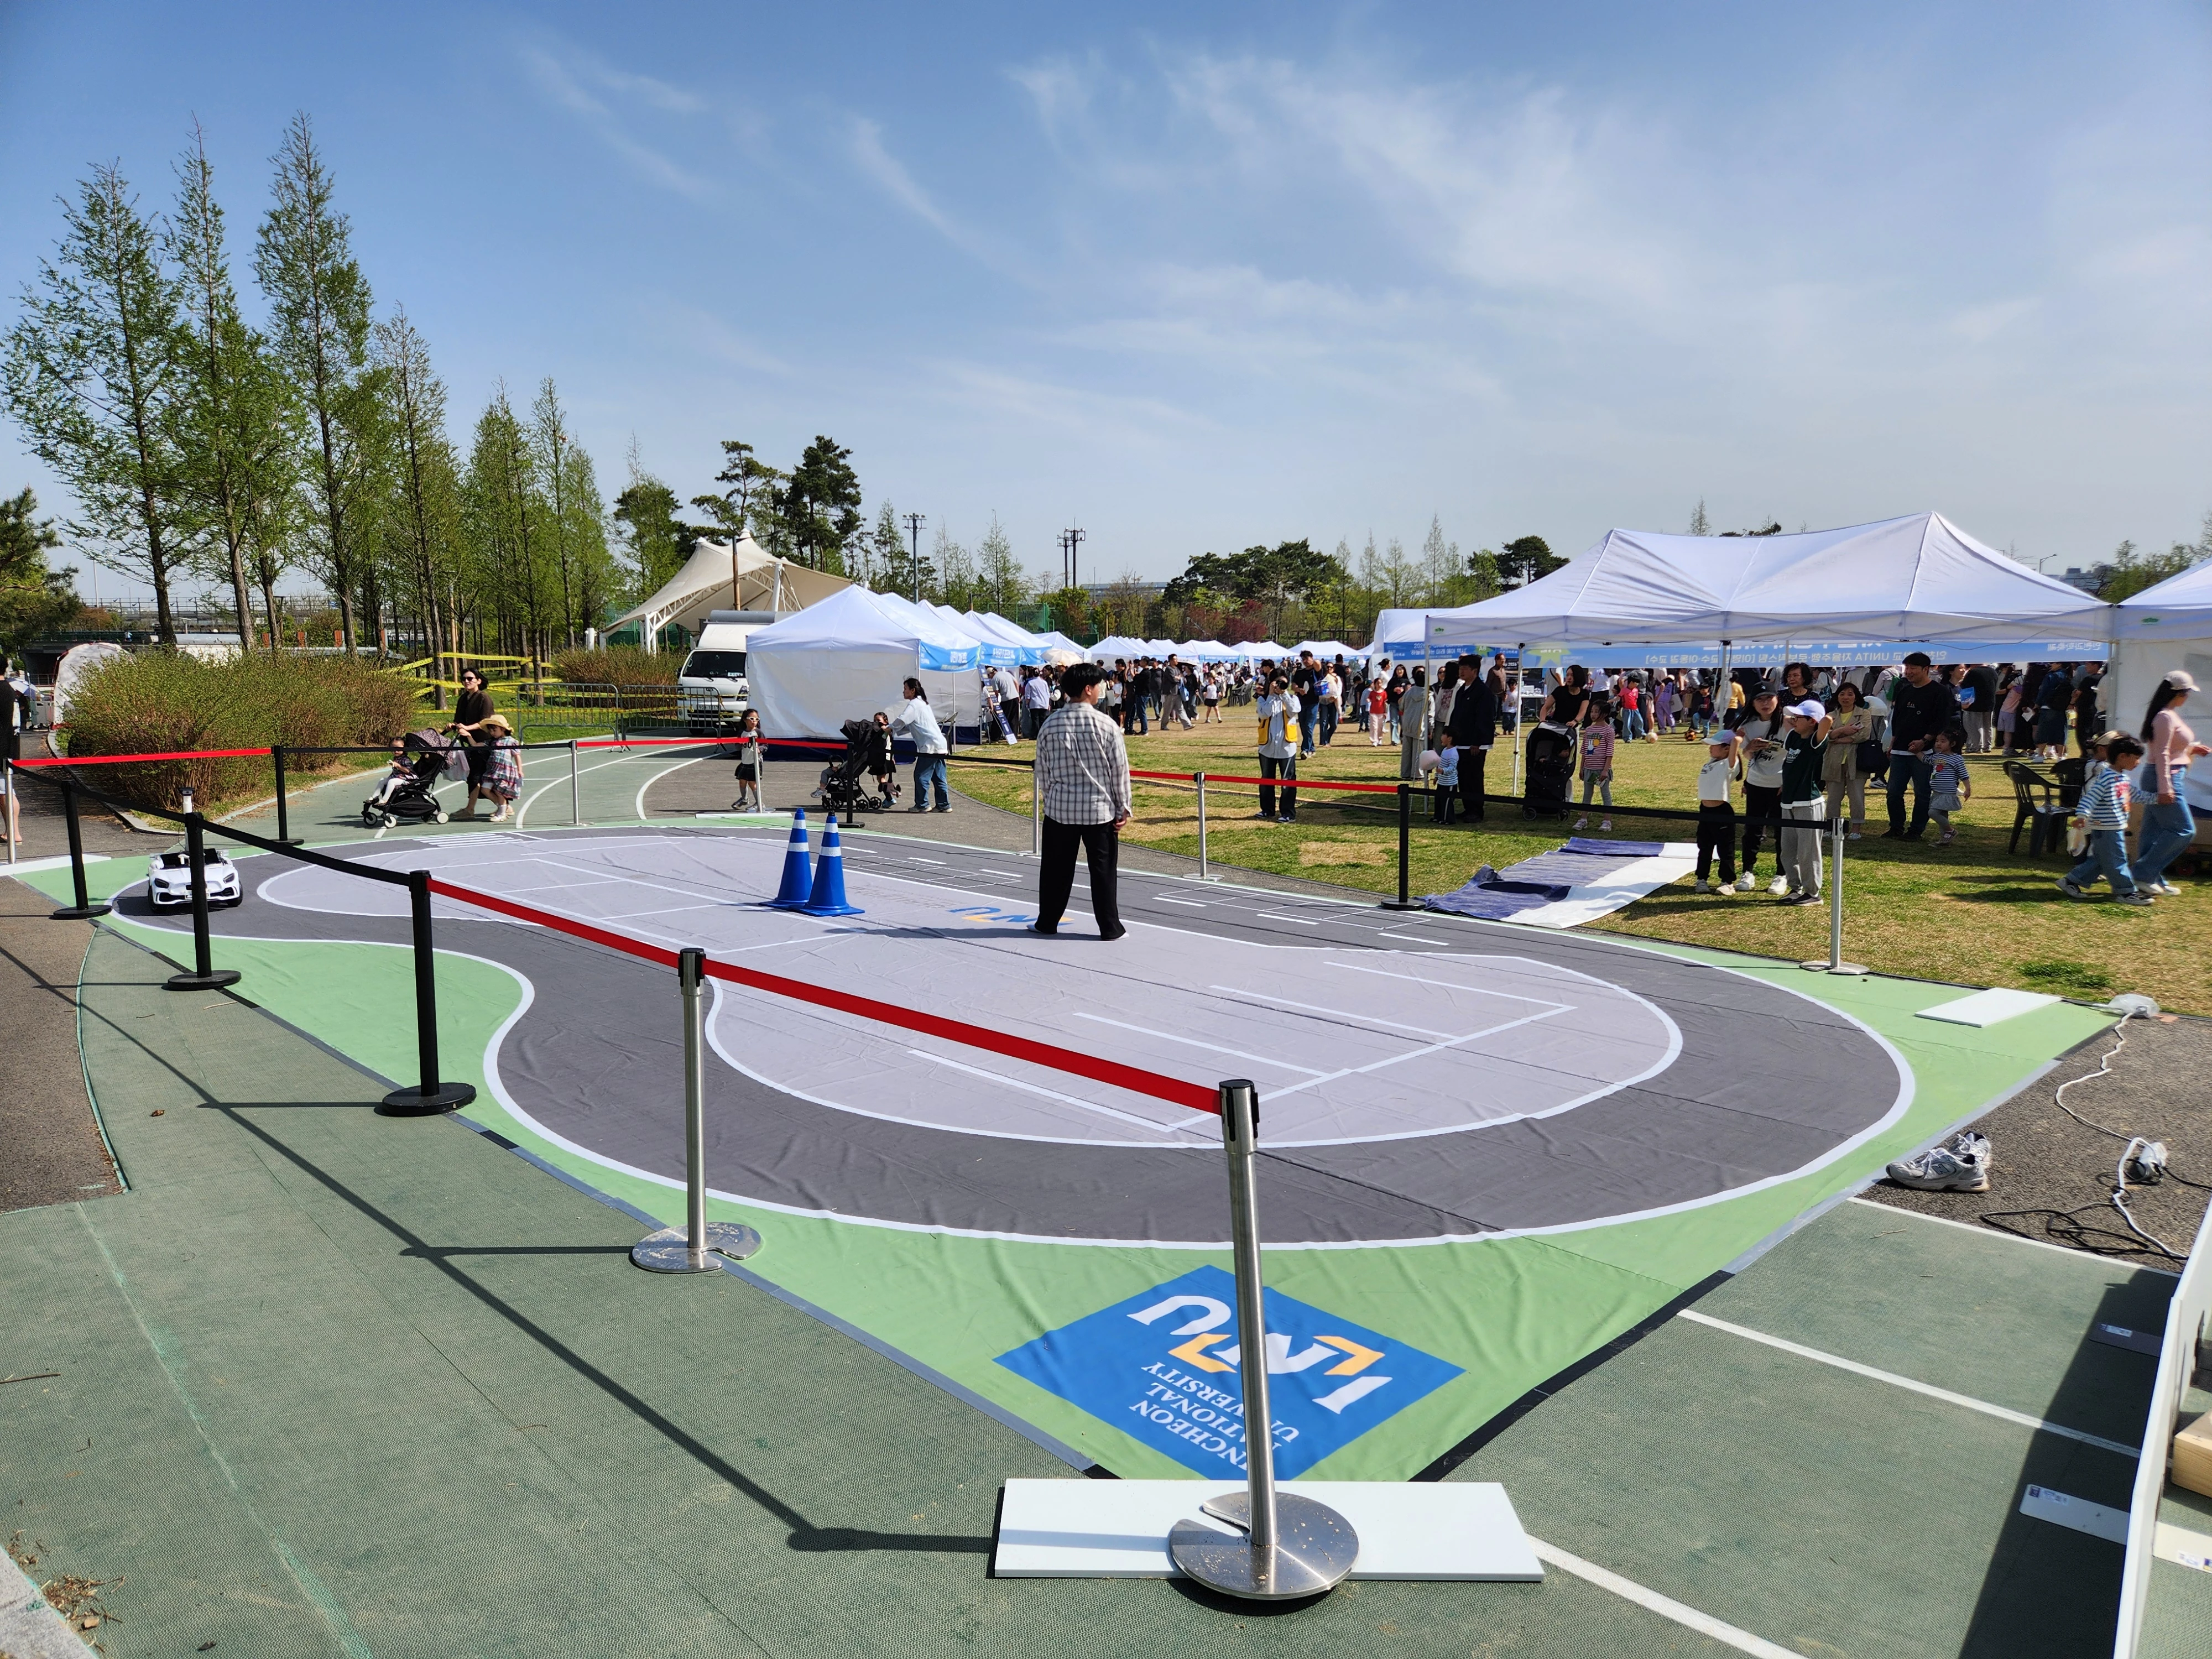
We combine RTK-GNSS/IMU navigation with Pure Pursuit/PID control, route following, and vehicle–computer communication. Camera–3D LiDAR fusion supports object detection and obstacle avoidance, with field experiments at K-City.
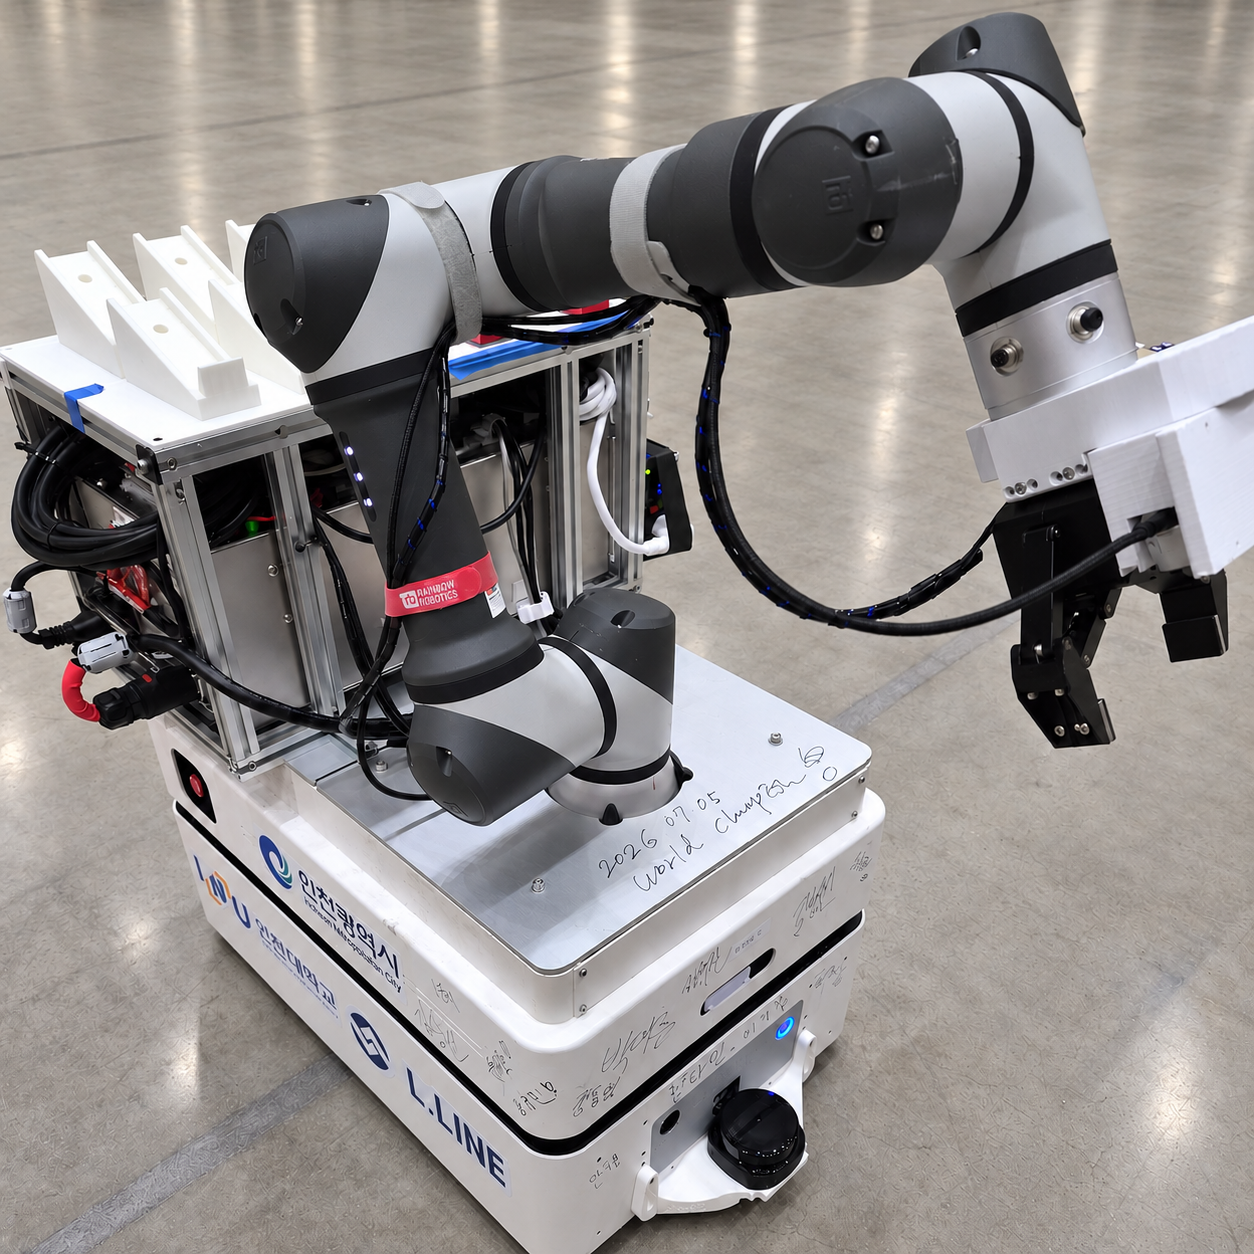
A mobile base and robotic arm combine navigation with manipulation on one platform. Our related demonstration presents autonomous navigation and task execution.
We integrate camera and 2D LiDAR sensing in a ROS 2 system. An Arduino handles low-level motor actuation, linking the sensing system with the stroller’s hardware.
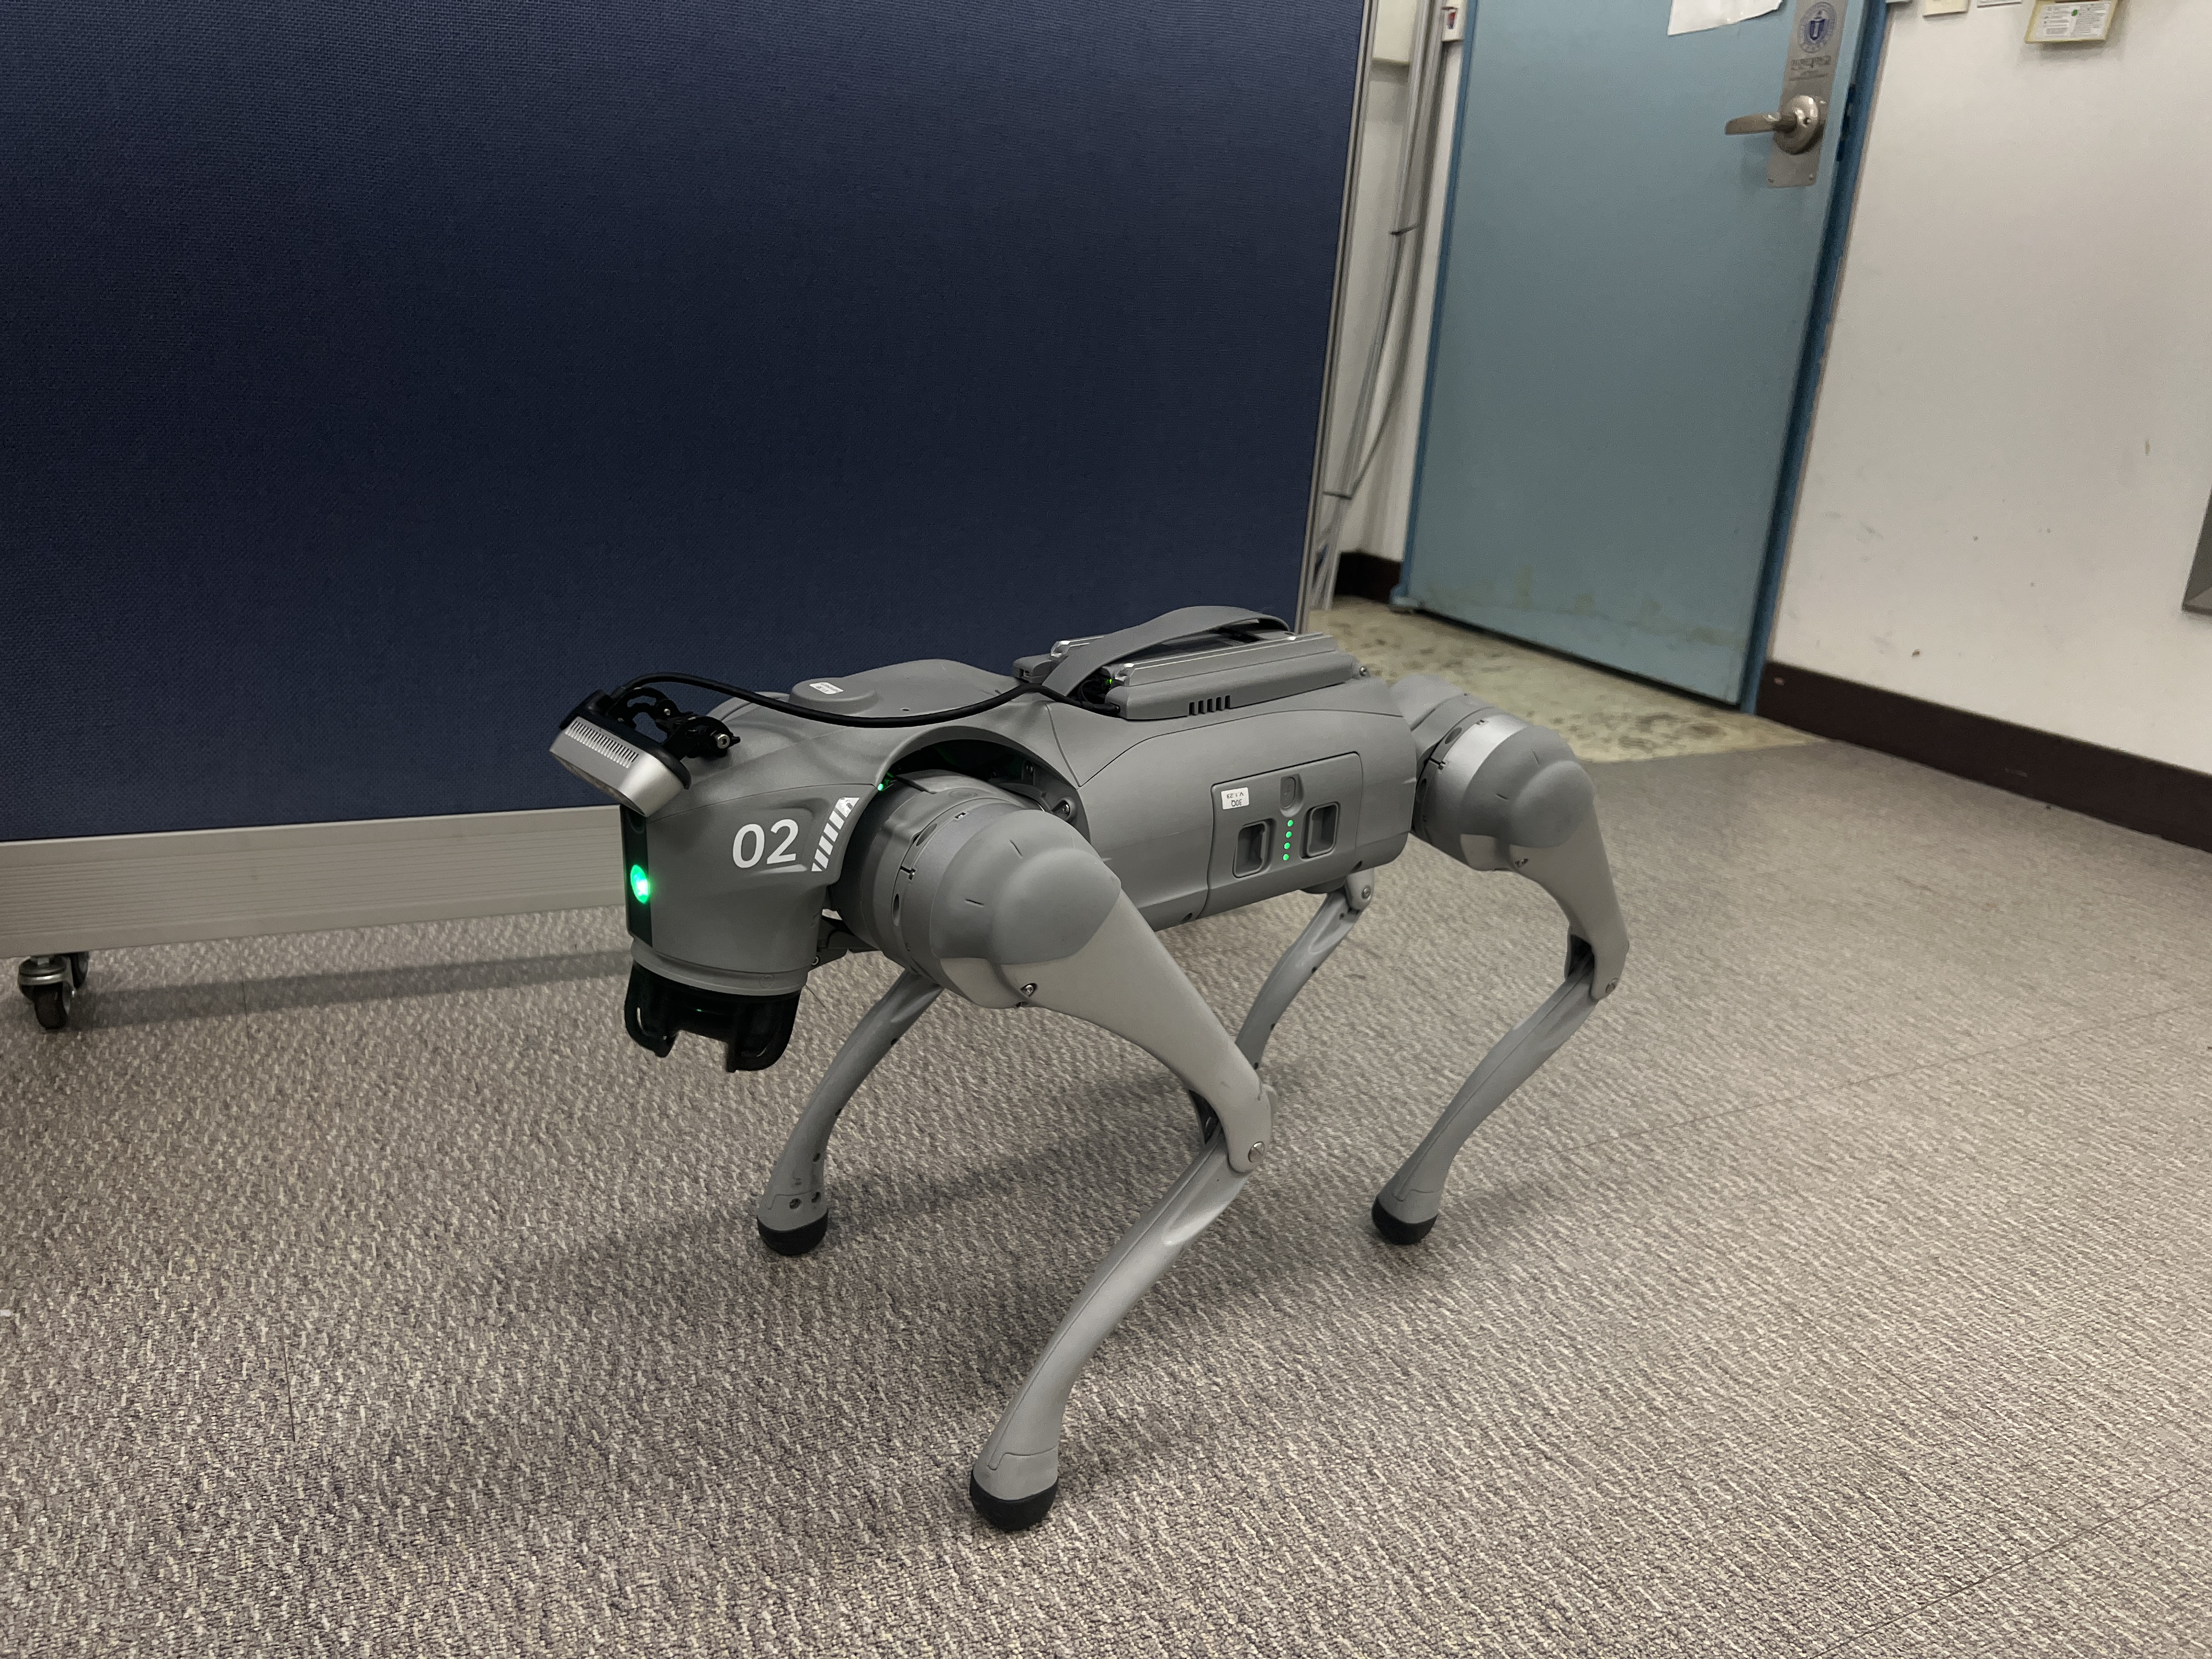
A four-legged platform extends the lab’s experimental systems beyond wheeled robots. It introduces legged mobility alongside our broader work on intelligent control and learning for autonomous systems.
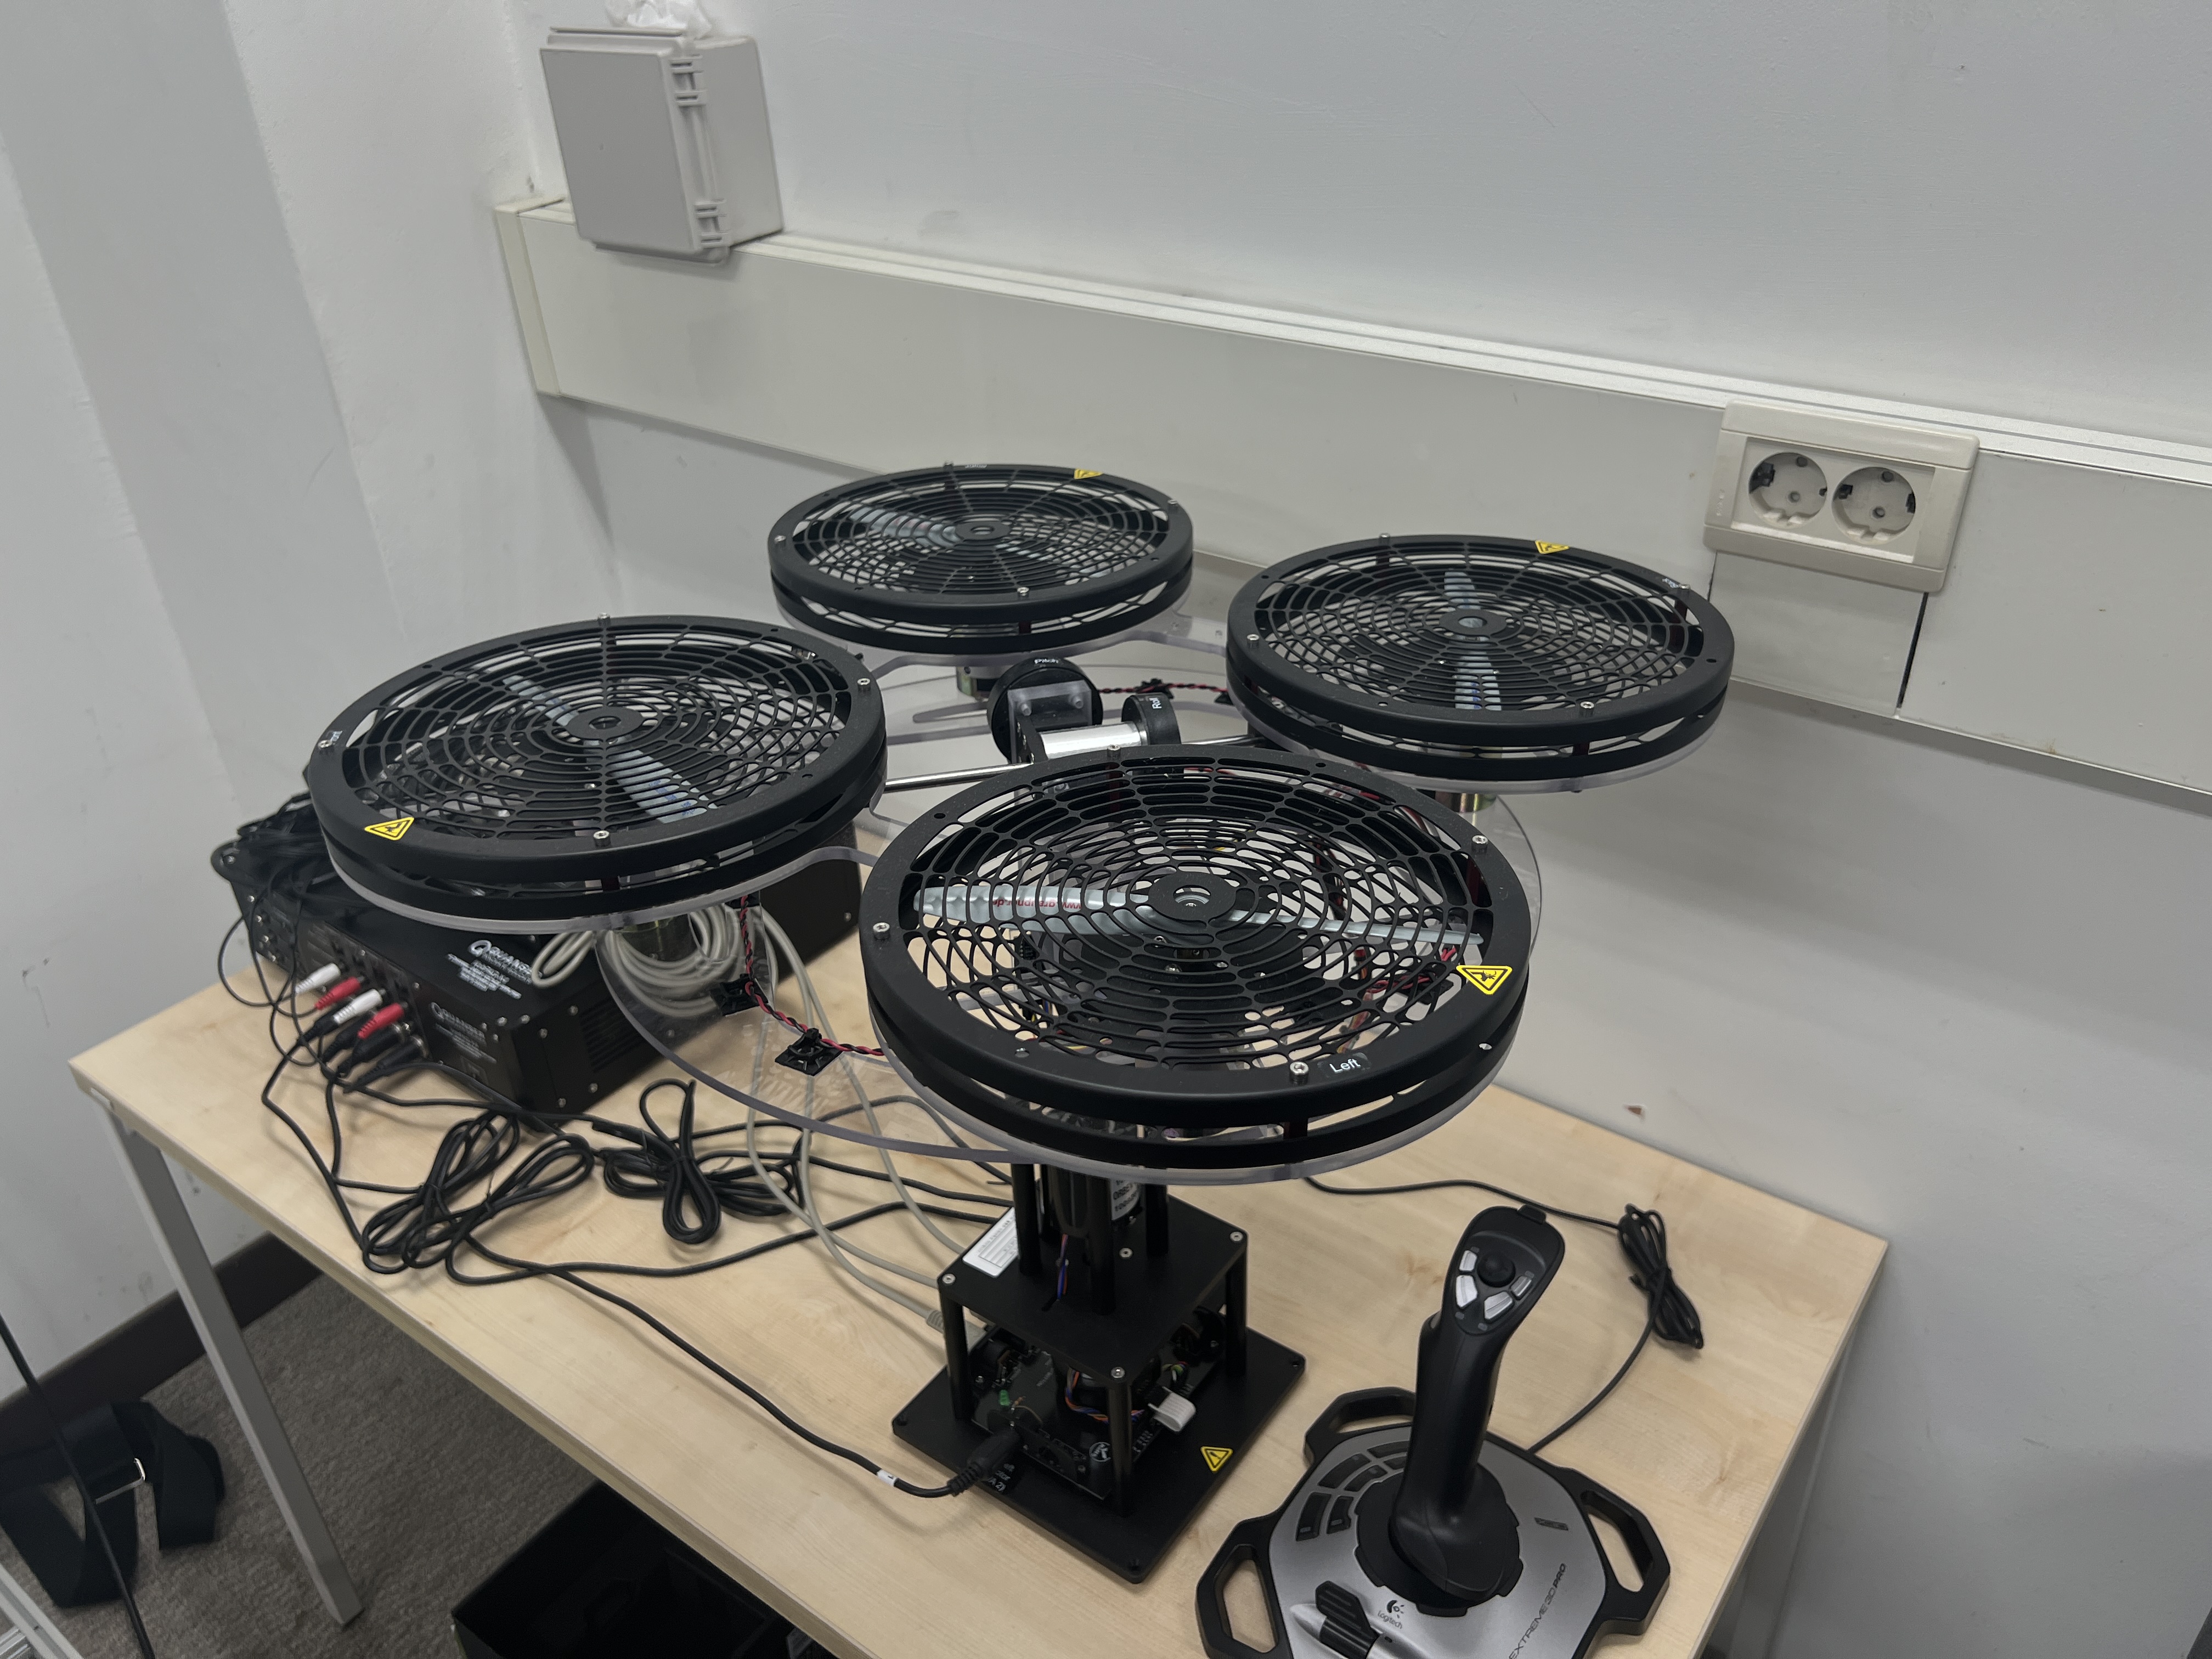
A laboratory quadrotor test platform complements the lab’s broader aerial-robotics research. Related work explores UAV path planning, collision avoidance, and learning-based control.
Seonjae Lee, Myoung Hoon Lee* and Jun Moon*, "Weight Vector Selection Methods by Hypervolume Maximization in the Pareto Front for Single Policy Multi-Objective Reinforcement Learning," Expert Systems with Applications, vol. 296, Part B, 129070, Jan. 2026.
Xinfeng Sun, Haotian Zhang, Myoung Hoon Lee* and Jun Moon*, "Option-based Deep Reinforcement Learning for Topology Control of Power Systems," IEEE Access, vol. 13, pp. 26639-26650, Feb. 2025.